
🔍 Read the full analysis: 5 Ways ToyBlocks Supports Robot Learning And Evaluation on ThorstenMeyerAI.com

Get the latest gadgets delivered free with Prime
- Fast, free delivery on millions of items
- Prime Video, Amazon Music and more included
- Member-only deals all year
TL;DR
Hugging Face has introduced ToyBlocks, an open simulated tabletop environment for training and evaluating robot arms on block-manipulation tasks. It can generate demonstrations and test models on tasks excluded from training, but the supplied material reports no model scores or physical-robot results.
Hugging Face has introduced ToyBlocks, an open simulation framework where researchers can train and evaluate robot arms on tabletop block tasks. The environment generates tasks and demonstrations and lets teams test performance on tasks withheld from training, offering a controlled way to study robot learning, as detailed in the original analysis; the announcement does not establish how well results transfer to physical robots.
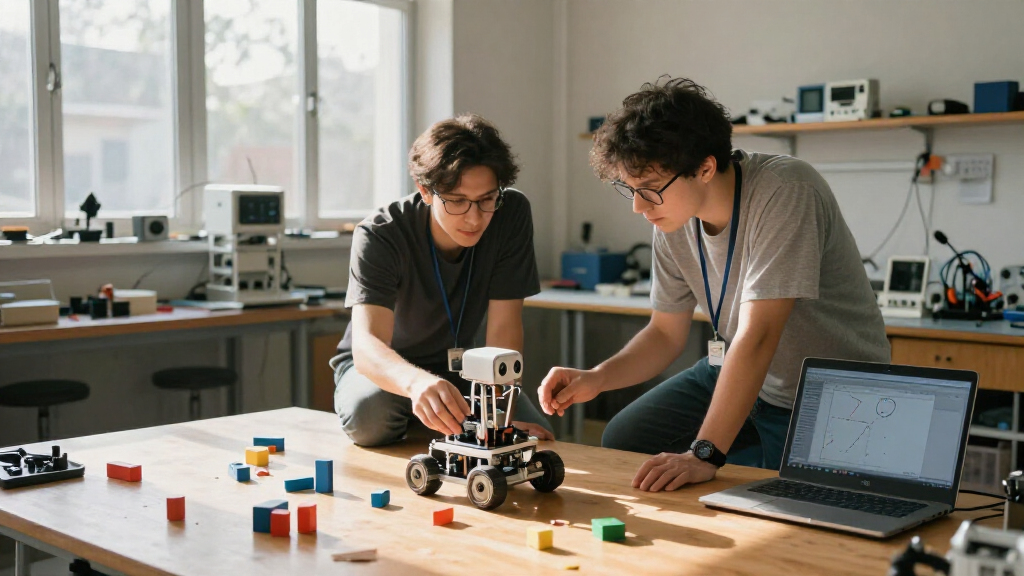
ToyBlocks centers on a simulated robot arm that can push, flip and stack marked blocks. Letters and pictures on the block faces allow researchers to define tasks involving searching, sorting and arranging. In some tasks, the robot must expose a hidden face before it can determine what to do. The environment can also vary properties such as block size and table height, allowing tests of how models respond to changes in geometry.
The framework automatically generates both tasks and demonstrations, which record a robot completing a task in simulation. A task-and-motion planner selects and sequences short skills, such as pushing or flipping, and plans movements between them. Hugging Face says hundreds of plans can run in parallel on one GPU at up to 24 times real-time speed. That is a company-reported simulation throughput figure; the source material gives no measurement setup or independent assessment.
Training combines reinforcement learning and motion planning in Isaac Lab, Nvidia’s open-source robot-learning simulation framework. The design separates high-level choices about which skill to use from lower-level control of movement. Researchers can change the mix of generated demonstrations—for example, using more pushing or flipping examples—and evaluate models on tasks not included in training. The described experiments are capabilities of the testbed, not reported findings: no scores or results showing the effect of changing the data mix are provided.
ToyBlocks tests robot skillsin a controlled world
Hugging Face introduced a simulated tabletop for training and evaluating robot arms. It helps researchers study how demonstrations shape performance on unfamiliar tasks.
A focused testbed
ToyBlocks limits the setting to a robot arm, a tabletop and marked blocks.
Move the blocks
Tasks include pushing, flipping and stacking, as well as searching, sorting and arranging.
Inspect before acting
Letters and pictures on block faces can require the robot to reveal a hidden face before deciding what to do.
How researchers use it
Generated demonstrations make it possible to vary training examples and evaluate skills on tasks held out from training.
A task-and-motion planner sequences short skills and plans movements between them.
Researchers can change how often examples involve skills such as pushing or flipping.
Evaluation on tasks excluded from training can show whether skills transfer within the simulated setting.
What the announcement establishes
ToyBlocks is the first environment in Hugging Face’s proposed FoundationWorlds framework.
- Hundreds of plans can run in parallel on one GPU.
- Hugging Face reports up to 24 times real-time simulation performance.
- No model scores or comparisons with other simulators are provided.
- No physical robot trial results show transfer to the real world.
Testing What Robot Data Teaches
ToyBlocks provides a simulated setting in which researchers can vary training demonstrations, hold other conditions steady and measure performance on tasks excluded from training. Such experiments can examine how models respond to different amounts or varieties of practice within the environment.
The tasks combine physical manipulation and visual reasoning: the robot moves blocks, while their markings determine the required action. ToyBlocks evaluates this combination of skills in a tabletop simulation. Whether results extend to other settings or to physical robots has not been established in the supplied material.
Products Worth Considering

DJI Mic 3 Wireless Microphone Kit (2 Transmitters, 1 Receiver, Charging Case)

Bose SoundLink Flex Bluetooth Speaker (2nd Gen), Black

Samsung Galaxy Tab A11+ 11-Inch Tablet, 6GB RAM, 128GB Storage, Expandable, Gray
As an affiliate, we earn on qualifying purchases.
A Narrow First FoundationWorld
Hugging Face presents FoundationWorlds as a proposed collection of controlled simulated environments for robot-learning research. The source describes each world as pairing a simulation with tools to generate tasks and demonstrations and measures to track robot behavior over time. ToyBlocks is the first example. The company’s earlier open robot-learning projects named in the source include MolmoAct 2, MolmoBot and MolmoSpaces.
The tabletop focus is a deliberate constraint. Rather than represent many objects and settings, ToyBlocks concentrates on one arm, a table and blocks, making it possible to vary tasks and physical properties within a limited domain. Hugging Face argues that this focus can support detailed simulation and many examples. The supplied material does not include comparative results showing how ToyBlocks performs against other simulation environments.
““Our first foundation world is ToyBlocks: an open simulation framework built around a robot arm and blocks on a tabletop.””
— Hugging Face
Simulation Gains, Real-World Limits
The source material does not report model scores, comparisons with other systems or results from experiments using different demonstration mixes. It describes how researchers could test held-out tasks but does not say how models performed on them. Hugging Face’s figure of up to 24 times real-time simulation speed is not accompanied by benchmark details or independent confirmation.
It is also unclear how well performance in ToyBlocks would carry over to a physical robot. The simulator can provide information such as a block’s exact position and orientation when generating skills, while a real system must infer such details from sensors. The source says models are also trained to map raw sensor observations to actions, but provides no physical-robot trial results or details on robustness to real-world variation.
Evidence Needed Beyond Simulation
Hugging Face says it aims to extend FoundationWorlds to more complex environments, but the source gives no timeline for another world or for further ToyBlocks evaluations. Future evaluation reports could provide held-out task performance, compare outcomes across demonstration mixes and explain the methods behind the simulation-speed figure.
Physical trials would provide evidence about whether findings from the simulated setting carry over to real robots. The supplied material reports no such results, so ToyBlocks is described as a framework for research experiments rather than as evidence of broad real-world robot capability.
Key Questions
What is ToyBlocks?
ToyBlocks is an open simulation environment from Hugging Face for training and evaluating a robot arm on tabletop tasks involving marked blocks.
What tasks can a robot perform in ToyBlocks?
The simulated arm can push, flip and stack blocks. Their letters and pictures can define tasks such as searching, sorting and arranging, including tasks that require revealing a hidden face.
Does ToyBlocks show that a robot will work in the physical world?
No physical-robot results are reported in the source material. Simulation performance alone does not establish real-world performance, where robots must rely on sensor observations and cope with physical variation.
Has Hugging Face reported model results from ToyBlocks?
The supplied material describes evaluations researchers can run, including tests on tasks withheld from training, but reports no model scores or findings from those experiments.
What does the 24-times-real-time figure mean?
Hugging Face says hundreds of plans can be generated and run in parallel on one GPU at up to 24 times real-time speed. The source does not specify the measurement method or provide independent verification.
Primary source: Hugging Face · via ThorstenMeyerAI.com